Propulsion
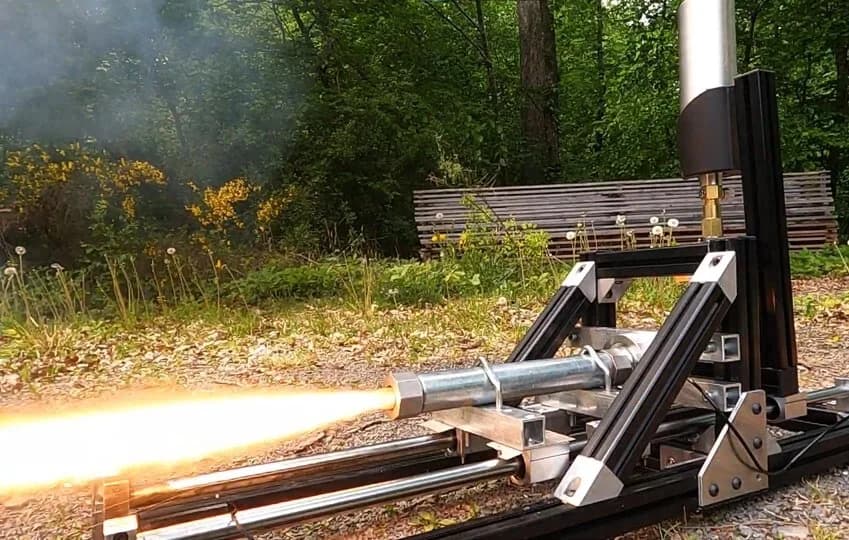
Hybrid rocket engine
Throttleable main engine on a gimbal for pitch and yaw control, without hydrazine.
The Leap Hopper
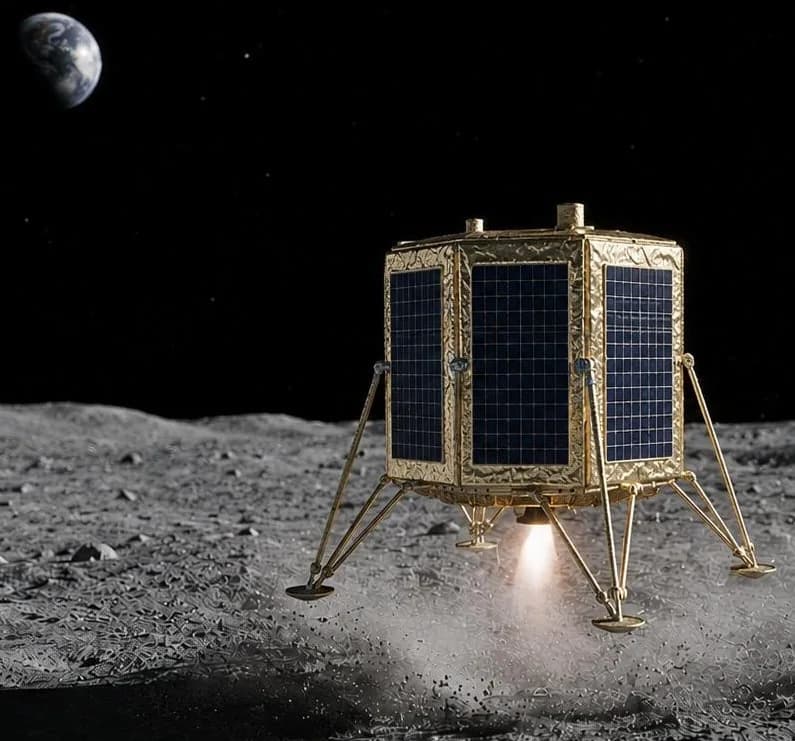
Fast, autonomous and able to land anywhere: the Leap Hopper maps the surface in flight and reaches terrain no rover can.
Specifications
A rocket-powered lunar drone that flies a mapping cruise or a series of ballistic hops, lands in craters and permanently shadowed regions, and fits on any lander.
Coverage vs. resolution
Orbiters map the complete lunar surface at meter scale. Rovers see centimetres, but only a football field. The Leap Hopper maps square kilometres at 15 cm resolution in a single mission.
Technology
We de-risk the most critical technologies early with working prototypes, and develop our own guidance, navigation and control.
Propulsion
Throttleable main engine on a gimbal for pitch and yaw control, without hydrazine.
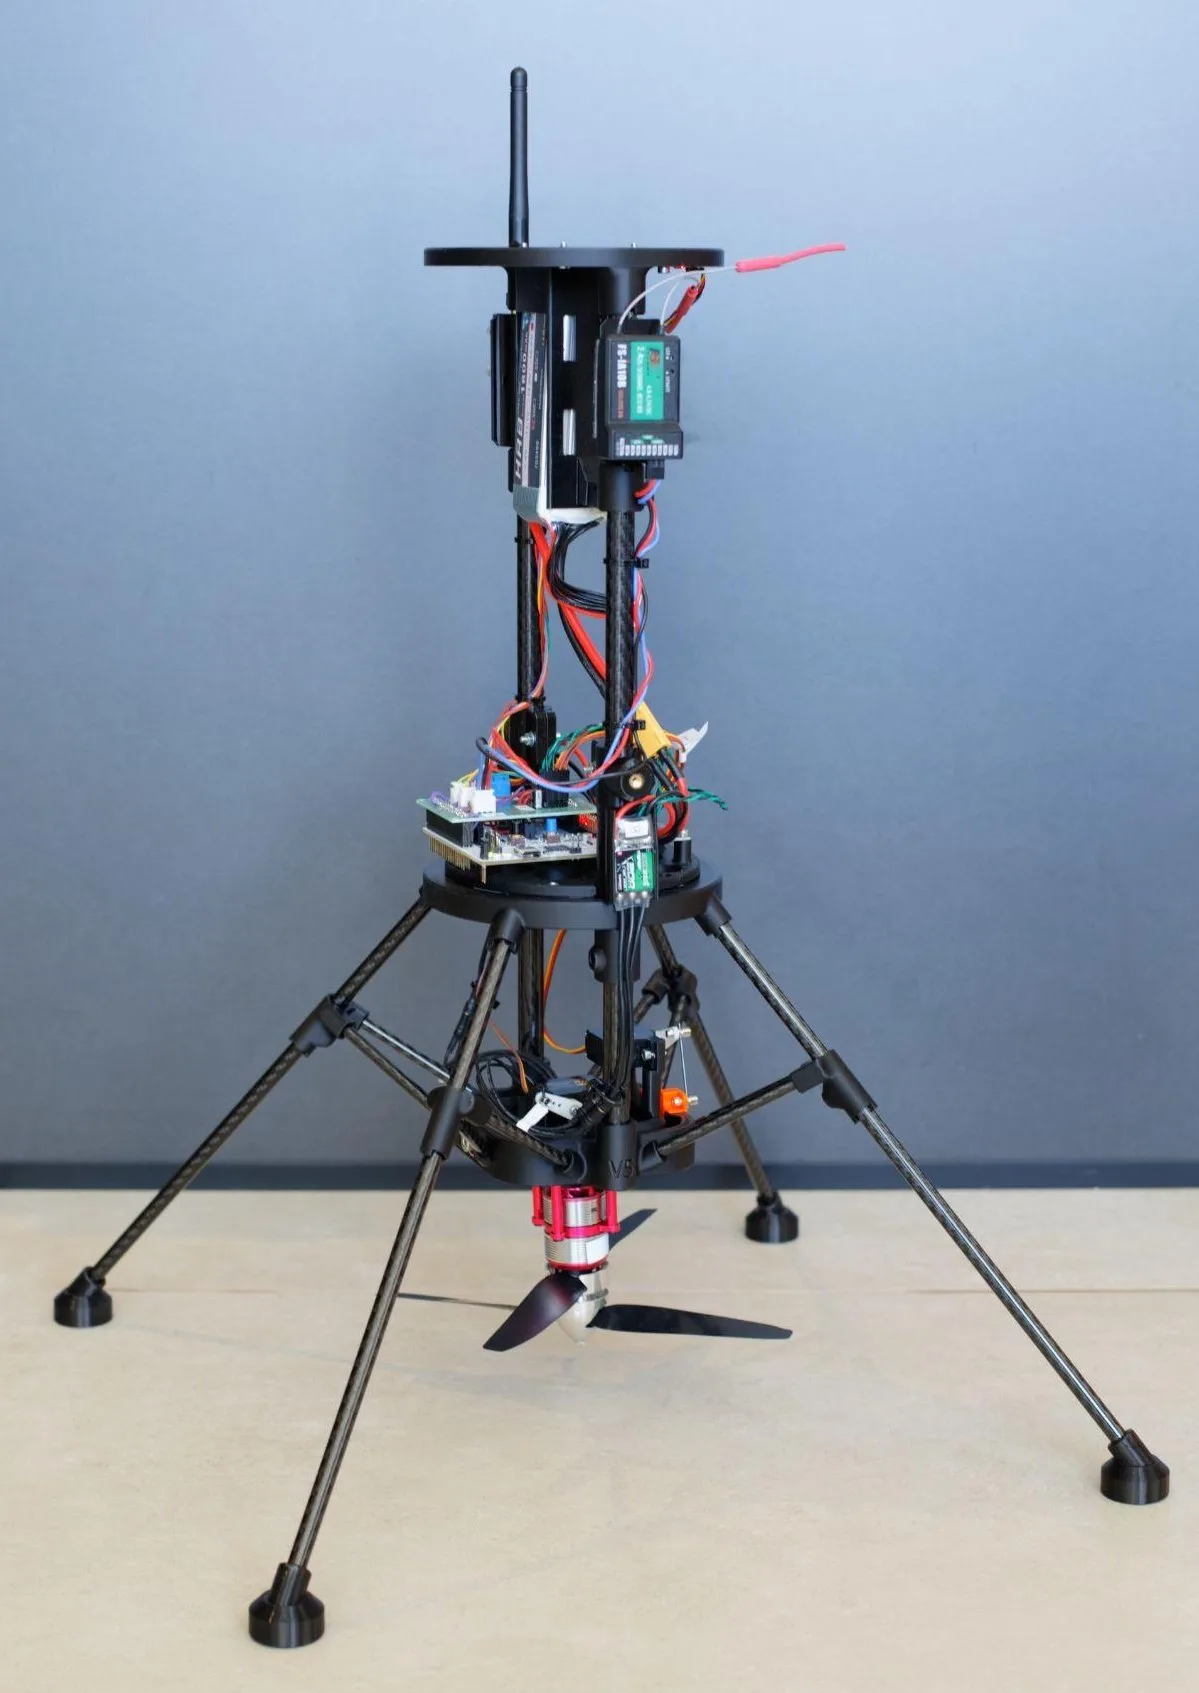
Navigation & guidance
3-beam FMCW LiDAR, terrain-matching camera and IMU. Camera and DEM above 200 m; LiDAR closes the loop to touchdown.
Control
One propellant load, three ways to fly it: a 16 km mapping cruise, seven 1.5 km hops, or one hop of up to 50 km. Model predictive control throughout.
10 kg of payload on every flight, plus high-resolution data from our own sensor suite.